A clean vtx drone installation is not only about choosing higher output power. In real FPV projects, horizontal lines, snow screen, image jumping, flicker, and sudden black screen often come from power noise, ground return, wire distance, antenna shadow, heat buildup, or a receiver-side mismatch.
Therefore, clean wiring should be checked before the VTX power level is selected. A 10W or 16W transmitter can perform well only when the power path, ground return, cable route, antenna position, cooling space, and receiver side are planned as one complete video link.
Start With the Visible Symptom, Not the Power Number
In drone FPV work, weak video rarely has one single cause. Distance reduces signal margin. Terrain blocks the path. Nearby wireless devices raise the noise floor. Meanwhile, the aircraft layout may damage the signal before it even leaves the drone.
Therefore, a clean diagnosis should begin with the image symptom. Snow that grows slowly at the far end is different from snow near takeoff. Likewise, image jumping during turns is different from a sudden black screen during a full-throttle climb.
This wiring-focused article explains how to keep 10W and 16W video clean through better power input, grounding, cable distance, antenna placement, cooling, and receiver checks. It also explains when 25W or OEM frequency planning makes sense for more demanding projects.
Fast Troubleshooting Map
| Image problem | Likely direction | Recommended check |
|---|---|---|
| Snow grows with distance | Low RF margin | Receiver height, antenna direction, VTX power class |
| Snow appears nearby | Power noise or channel conflict | Grounding, cable routing, exact channel match |
| Image breaks during turns | Antenna shadow or angle loss | Antenna location, polarization, receiver diversity |
| Sudden black screen | Power drop, heat, camera, or connector interruption | Voltage log, warm test, connector vibration check |
Power Input and Grounding Decide Image Cleanliness
First, a 10W or 16W analog video transmitter needs stable input power under real load. A module may look normal on the bench, yet show rolling lines when motors, gimbals, payloads, and telemetry devices start working together. As a result, the power source should be checked during throttle movement, not only during idle operation.
A direct regulated power path is usually safer than a convenient accessory rail. In addition, the wire should be thick enough for the current demand and short enough to reduce voltage drop. If the aircraft uses a shared battery, the transmitter should still avoid thin shared wires that also feed servos, LEDs, or noisy payload devices.
Grounding is just as important. A poor ground path can carry ESC switching noise, servo pulses, and current spikes into the video system. Therefore, the ground return should be direct, low-resistance, and secure after vibration, heat cycles, and field maintenance.
For larger aircraft, a star ground layout is often cleaner. In this layout, key modules return to a common power distribution point instead of passing through several devices. This reduces the chance that the video transmitter shares noisy return current from propulsion hardware.

A 10W transmitter is suitable for medium-range UAV video projects when power input, ground return, and antenna clearance are planned together.
Cable Distance and Antenna Position Reduce Hidden Loss
Cable routing can create noise before any long-distance test begins. Battery-to-ESC wires carry fast switching current, so video signal lines and transmitter control wires should not run beside them for long distances. If the lines must cross, a short right-angle crossing is usually cleaner than a long parallel run.
At the same time, antenna cable quality matters. A loose SMA connector, damaged coax cable, or sharp cable bend can reduce useful RF output. Consequently, the screen may show snow even when the selected VTX power class looks correct on paper.
Antenna location also deserves more attention than many builds receive. Carbon fiber, batteries, gimbals, metal brackets, payload shells, and landing gear can block or reflect the signal. Therefore, the antenna should sit where it has the clearest path during the actual flight attitude.
This is especially important for a vtx drone used in fixed-wing cruising, VTOL transition, hill inspection, forest edge routes, industrial parks, or multi-aircraft training. In these scenes, small layout losses can become visible when the aircraft turns, climbs, or flies behind partial obstacles.
Wiring layout rules that usually improve the image
- Keep VTX power wires away from ESC and motor power lines whenever the frame allows it.
- Use a stable regulator with enough current headroom instead of a weak accessory output.
- Place the antenna away from carbon fiber, battery packs, metal plates, and enclosed payload shells.
- Check SMA connectors, coax cables, JST plugs, and solder joints after vibration testing.
- Run a warm test because a clean startup image may become noisy after continuous high-power operation.
Match 10W, 16W, and 25W to Real Flight Scenes
The best VTX choice should follow the symptom and the route. A larger power number does not automatically solve poor wiring, blocked antennas, receiver mismatch, or heat buildup. Instead, 10W, 16W, and 25W should be selected after the aircraft layout and flight environment are understood.
For open-field work, rural inspection, agricultural routes, medium-distance testing, and training fleets, the 5.8GHz 10W 80CH drone VTX is a practical upgrade. It is useful when snow mainly appears near the expected range limit and the receiver side is already reasonable.
For mixed environments, the 5.8GHz 16W low latency VTX is often the stronger middle choice. It fits industrial park inspection, suburban routes, long corridors, rolling hills, light woodland, fixed-wing cruise missions, and high-speed FPV applications that need more margin during turns.
For severe distance pressure, large UAV platforms, open-area industrial missions, emergency monitoring, and long fixed-wing routes, 25W can provide stronger headroom. However, 25W should be paired with stable power, clean grounding, secure mounting, correct antenna layout, and enough airflow.

A 16W low-latency transmitter is a strong choice for inspection drones, mixed RF environments, and routes that need more reserve during movement.
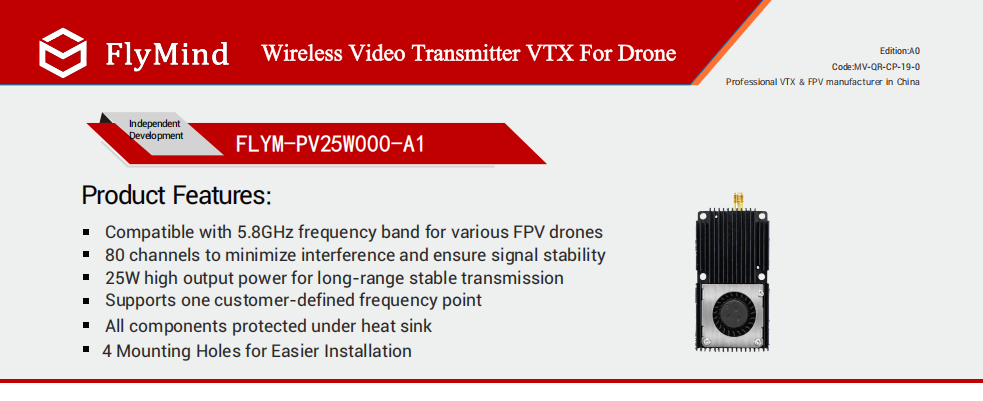
25W should be used for serious long-range projects where aircraft power, cooling, receiver layout, and antenna design are ready for high-output work.
Installation and Receiver Checks That Decide Stability
Even a high-power VTX can perform poorly when the receiver side is weak. A low ground antenna, long lossy cable, wrong polarization, blocked receiving position, or poor pointing angle can make a strong airborne transmitter look unstable. Because of this, every test should include the complete link, not only the onboard module.
Cooling is another key detail. High-power analog VTX modules create heat during long operation. Therefore, the heat sink should face airflow, and the module should not be sealed inside foam, tape, or a narrow plastic pocket. A warm runtime test is more useful than a short bench power-on check.
For city, industrial park, multi-drone, OEM, or special anti-interference scenes, 6-7GHz planning can be considered. However, receiver compatibility, antenna matching, frequency permission, and actual test distance should be confirmed before changing band strategy. In most standard analog projects, 5.8GHz 10W and 16W remain the main practical path.
The OEM custom video transmission service can support project-specific interface, frequency, antenna, power, and structural requirements. This is useful when several aircraft share one platform family and need repeatable wiring quality across batch integration.

OEM planning can define interface direction, wire length, antenna setup, channel strategy, frequency selection, and batch installation standards.
Testing and Procurement Checklist Before Batch Integration
A useful VTX test should not focus only on maximum distance. Instead, it should confirm whether the image stays predictable during the real route. Repeated tests reveal turn loss, heat movement, channel noise, terrain shadow, receiver weakness, and power instability.
First, record a baseline in open space. Include distance, altitude, receiver height, antenna type, channel, weather, route direction, battery voltage, and visible image quality. Then, test the expected work scene, because farmland, forest edge, hills, industrial parks, coastlines, and urban-edge flights create different signal conditions.
Finally, run a heat and vibration check. A short bench test proves only that the system powers on. A mission-level runtime test shows whether the module, connector, power supply, cooling layout, and receiver side can support repeated field use.
Recommended test order
- Start with exact channel confirmation and receiver antenna inspection.
- Test transmitter input voltage under throttle and payload load.
- Fly the same route at two safe altitudes to compare path loss.
- Repeat far-end turns to check antenna shadow and polarization loss.
- Record image quality after warm operation, not only at startup.
Before procurement, the project file should include aircraft type, target distance, flight environment, frequency preference, receiver model, antenna setup, battery voltage, quantity, and OEM or ODM requirements. This information helps match 10W, 16W, 25W, or special-frequency options without relying on guesswork.
FAQ
Why does FPV video show horizontal lines during throttle?
Horizontal lines during throttle usually point to power ripple or ground noise. ESC switching current may enter the video system through shared wiring. A cleaner regulator, direct ground return, better cable separation, and LC filtering can reduce this problem.
Can 16W solve all snow screen problems?
No. A 16W transmitter improves RF margin, but it cannot fully solve wrong channels, damaged antennas, blocked antenna paths, voltage drop, poor grounding, or overheating. The complete link must be checked before judging power level.
When is 10W enough for a drone video link?
10W is often enough for medium-distance open routes, rural inspection, agricultural scouting, campus patrol, training fleets, and projects where snow appears mainly near the range limit. The receiver side and antenna layout should already be reasonable.
When should 25W be considered?
25W makes sense for larger UAV platforms, serious long-range routes, open-area industrial missions, emergency monitoring, and heavy-duty fixed-wing work. However, the aircraft must support stable power, airflow, secure antenna installation, and reliable receiver setup.
Why does the image break only during turns?
During turns, the aircraft body, battery, landing gear, or payload shell may block the antenna path. In addition, antenna angle and polarization may change quickly. Better antenna placement and receiver diversity can reduce this issue.
Should 6-7GHz be used for every anti-interference project?
No. 6-7GHz should be used for special anti-interference, city inspection, OEM frequency planning, or custom channel projects. Receiver compatibility, antenna matching, allowed frequency use, and test distance should be confirmed first.
What information should be sent before selecting a VTX?
The useful details include drone type, target distance, flight environment, frequency preference, receiver setup, antenna type, battery voltage, order quantity, and whether OEM or ODM customization is needed.
Summary and Inquiry Checklist
In summary, clean video starts with the full system. Power output matters, but wiring quality, ground return, antenna clearance, cooling, receiver height, and channel planning decide whether the image stays stable in real flight.
For a stable FlyMind vtx drone project, send the aircraft type, target distance, flight environment, frequency preference, receiving side, quantity, and OEM/ODM needs. These details help match 10W, 16W, or 25W more accurately.
Three action steps
- First, record the exact symptom: snow screen, horizontal lines, jumping image, black screen, or disconnection.
- Second, check the complete link: power input, ground, antenna position, receiver height, cooling, and channel match.
- Finally, choose the power class: 10W for practical range, 16W for stronger mixed-scene margin, and 25W for serious long-range industrial work.


